Rover Team
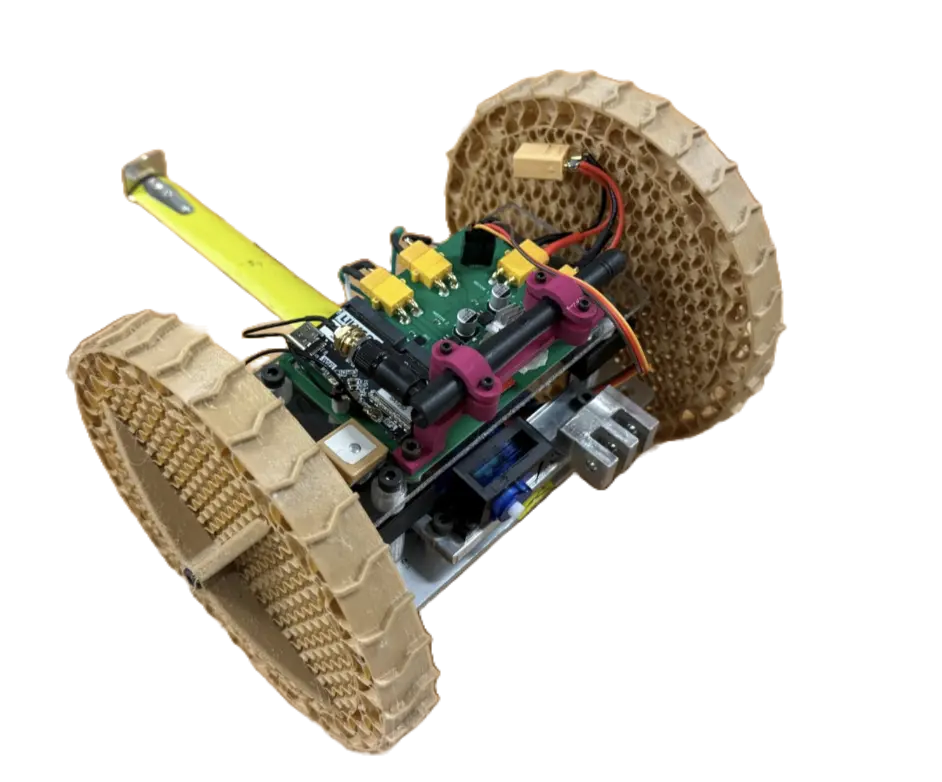
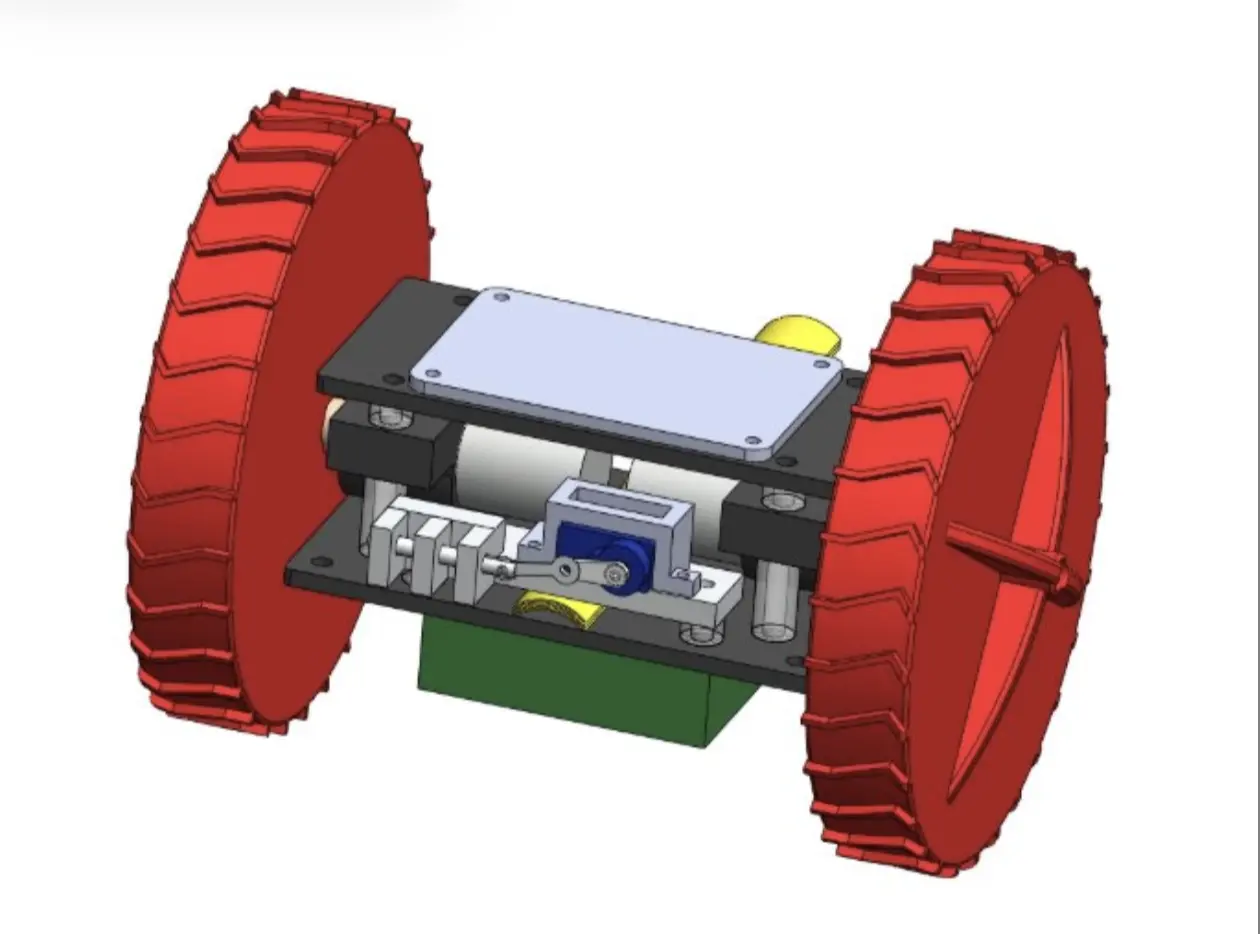
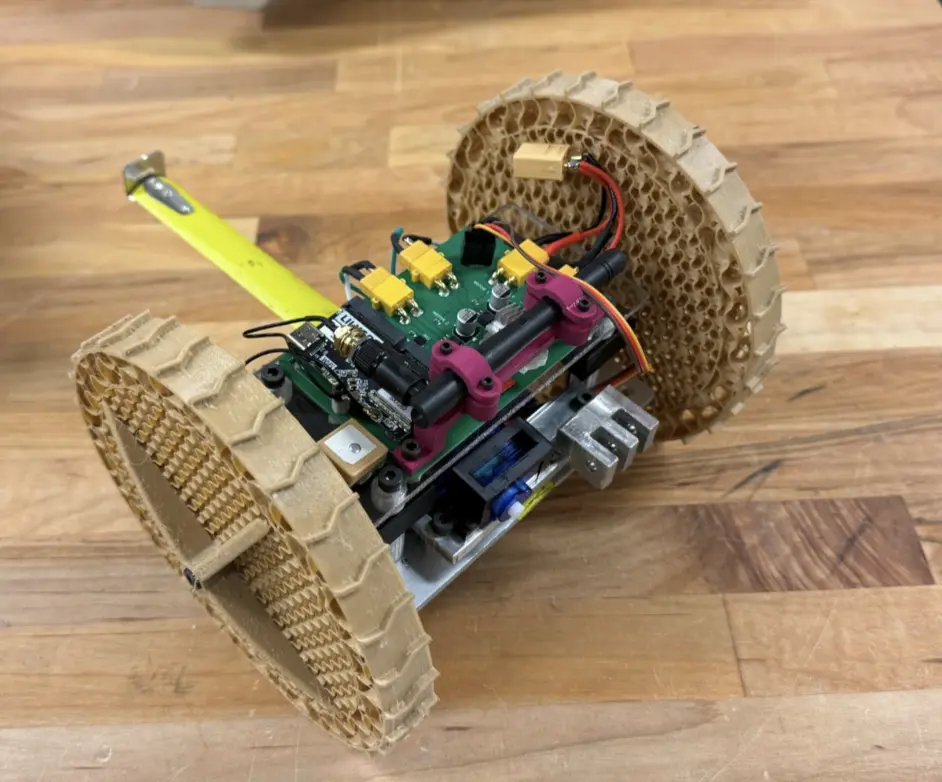
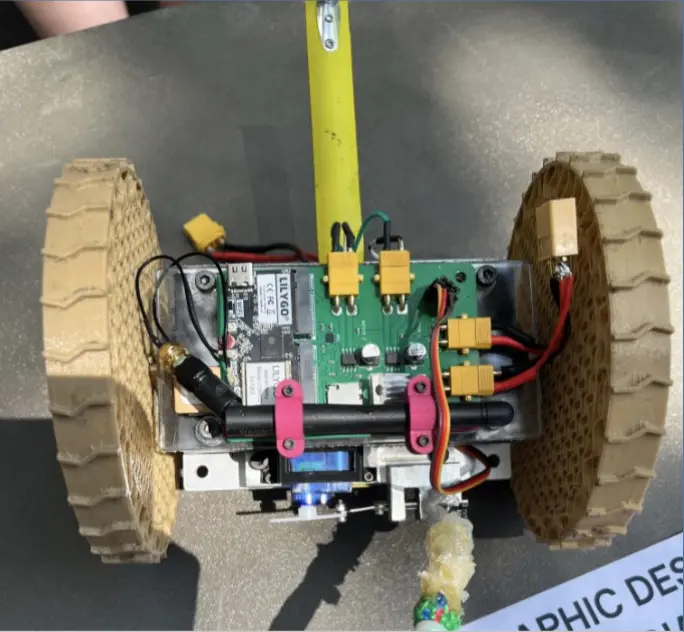
A two-wheel autonomous rover designed for reliable navigation after landing.
COMPETITION: ARLISS
- 820 g
- Mass
- 1.0 m/s
- Top speed
- 2
- Competitions
Design goal
Design a 2-wheeled GPS autonomous rover capable of parachuting out of a rocket at 15,000', landing, and navigating to a predetermined location.
How it works
The rover works by controlling motor speeds based off of GPS heading and position. This allows the rover to consistently get within 2.5 m of a target. For next year's rover, we will be using a 2-D LiDAR to determine the position of the target when we are within 2.5 m, and driving to the exact position.
Gallery
General Specifications
- Mass
- 820 g
- Chassis size (L × W × H)
- 13 × 6 × 4 cm
- Top speed
- 1.0 m/s
- Microcontroller
- ESP32-S3
- Navigation
- GPS + IMU
- Competitions
- 2
Meet the Team
Luca Baldelli
Rover Team Lead
Harineel Gajelli
Mechanical Engineering
Katie Aycock
Mechanical Engineering
Zane Plante
Aerospace Engineering
Liam Resnick
Computer Science
Arsenii Toradze
Computer Engineering