Glider Team
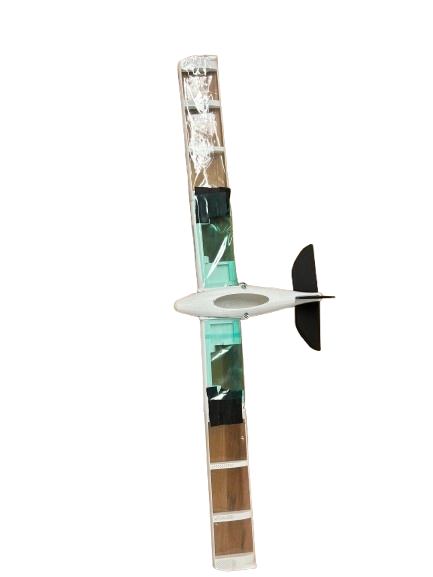
An autonomous glider designed to reach the target on landing.
COMPETITION: ARLISS
- 250 g
- Mass
- 66 cm
- Wingspan
- 0
- Competitions
Design goal
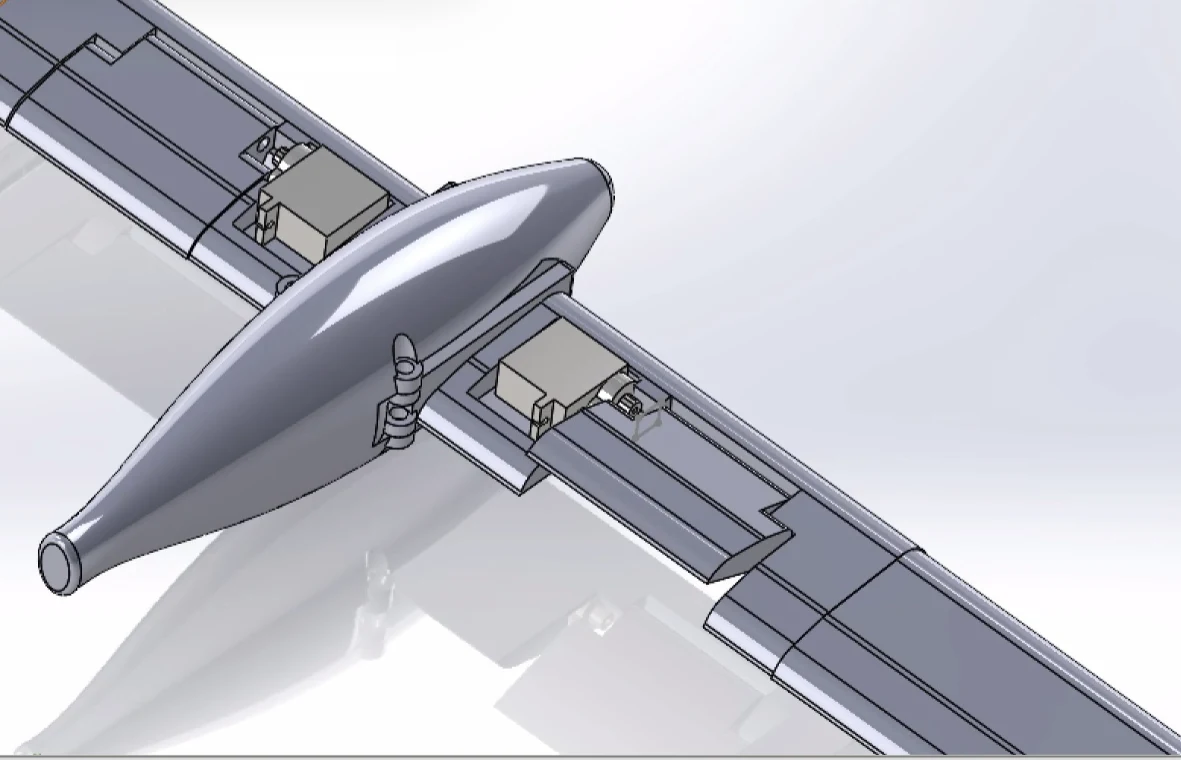
The design goal of the glider is to reach the target with a propulsion-less, controls-only glide. This project is meant to be a unique solution to achieve the requirements set by the Cansat competition, as no other teams have attempted a glider as of yet.
How it works
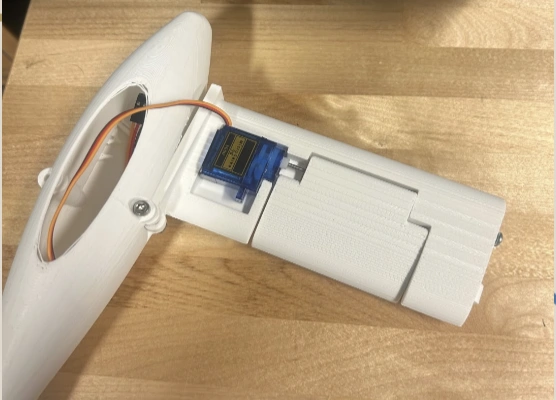
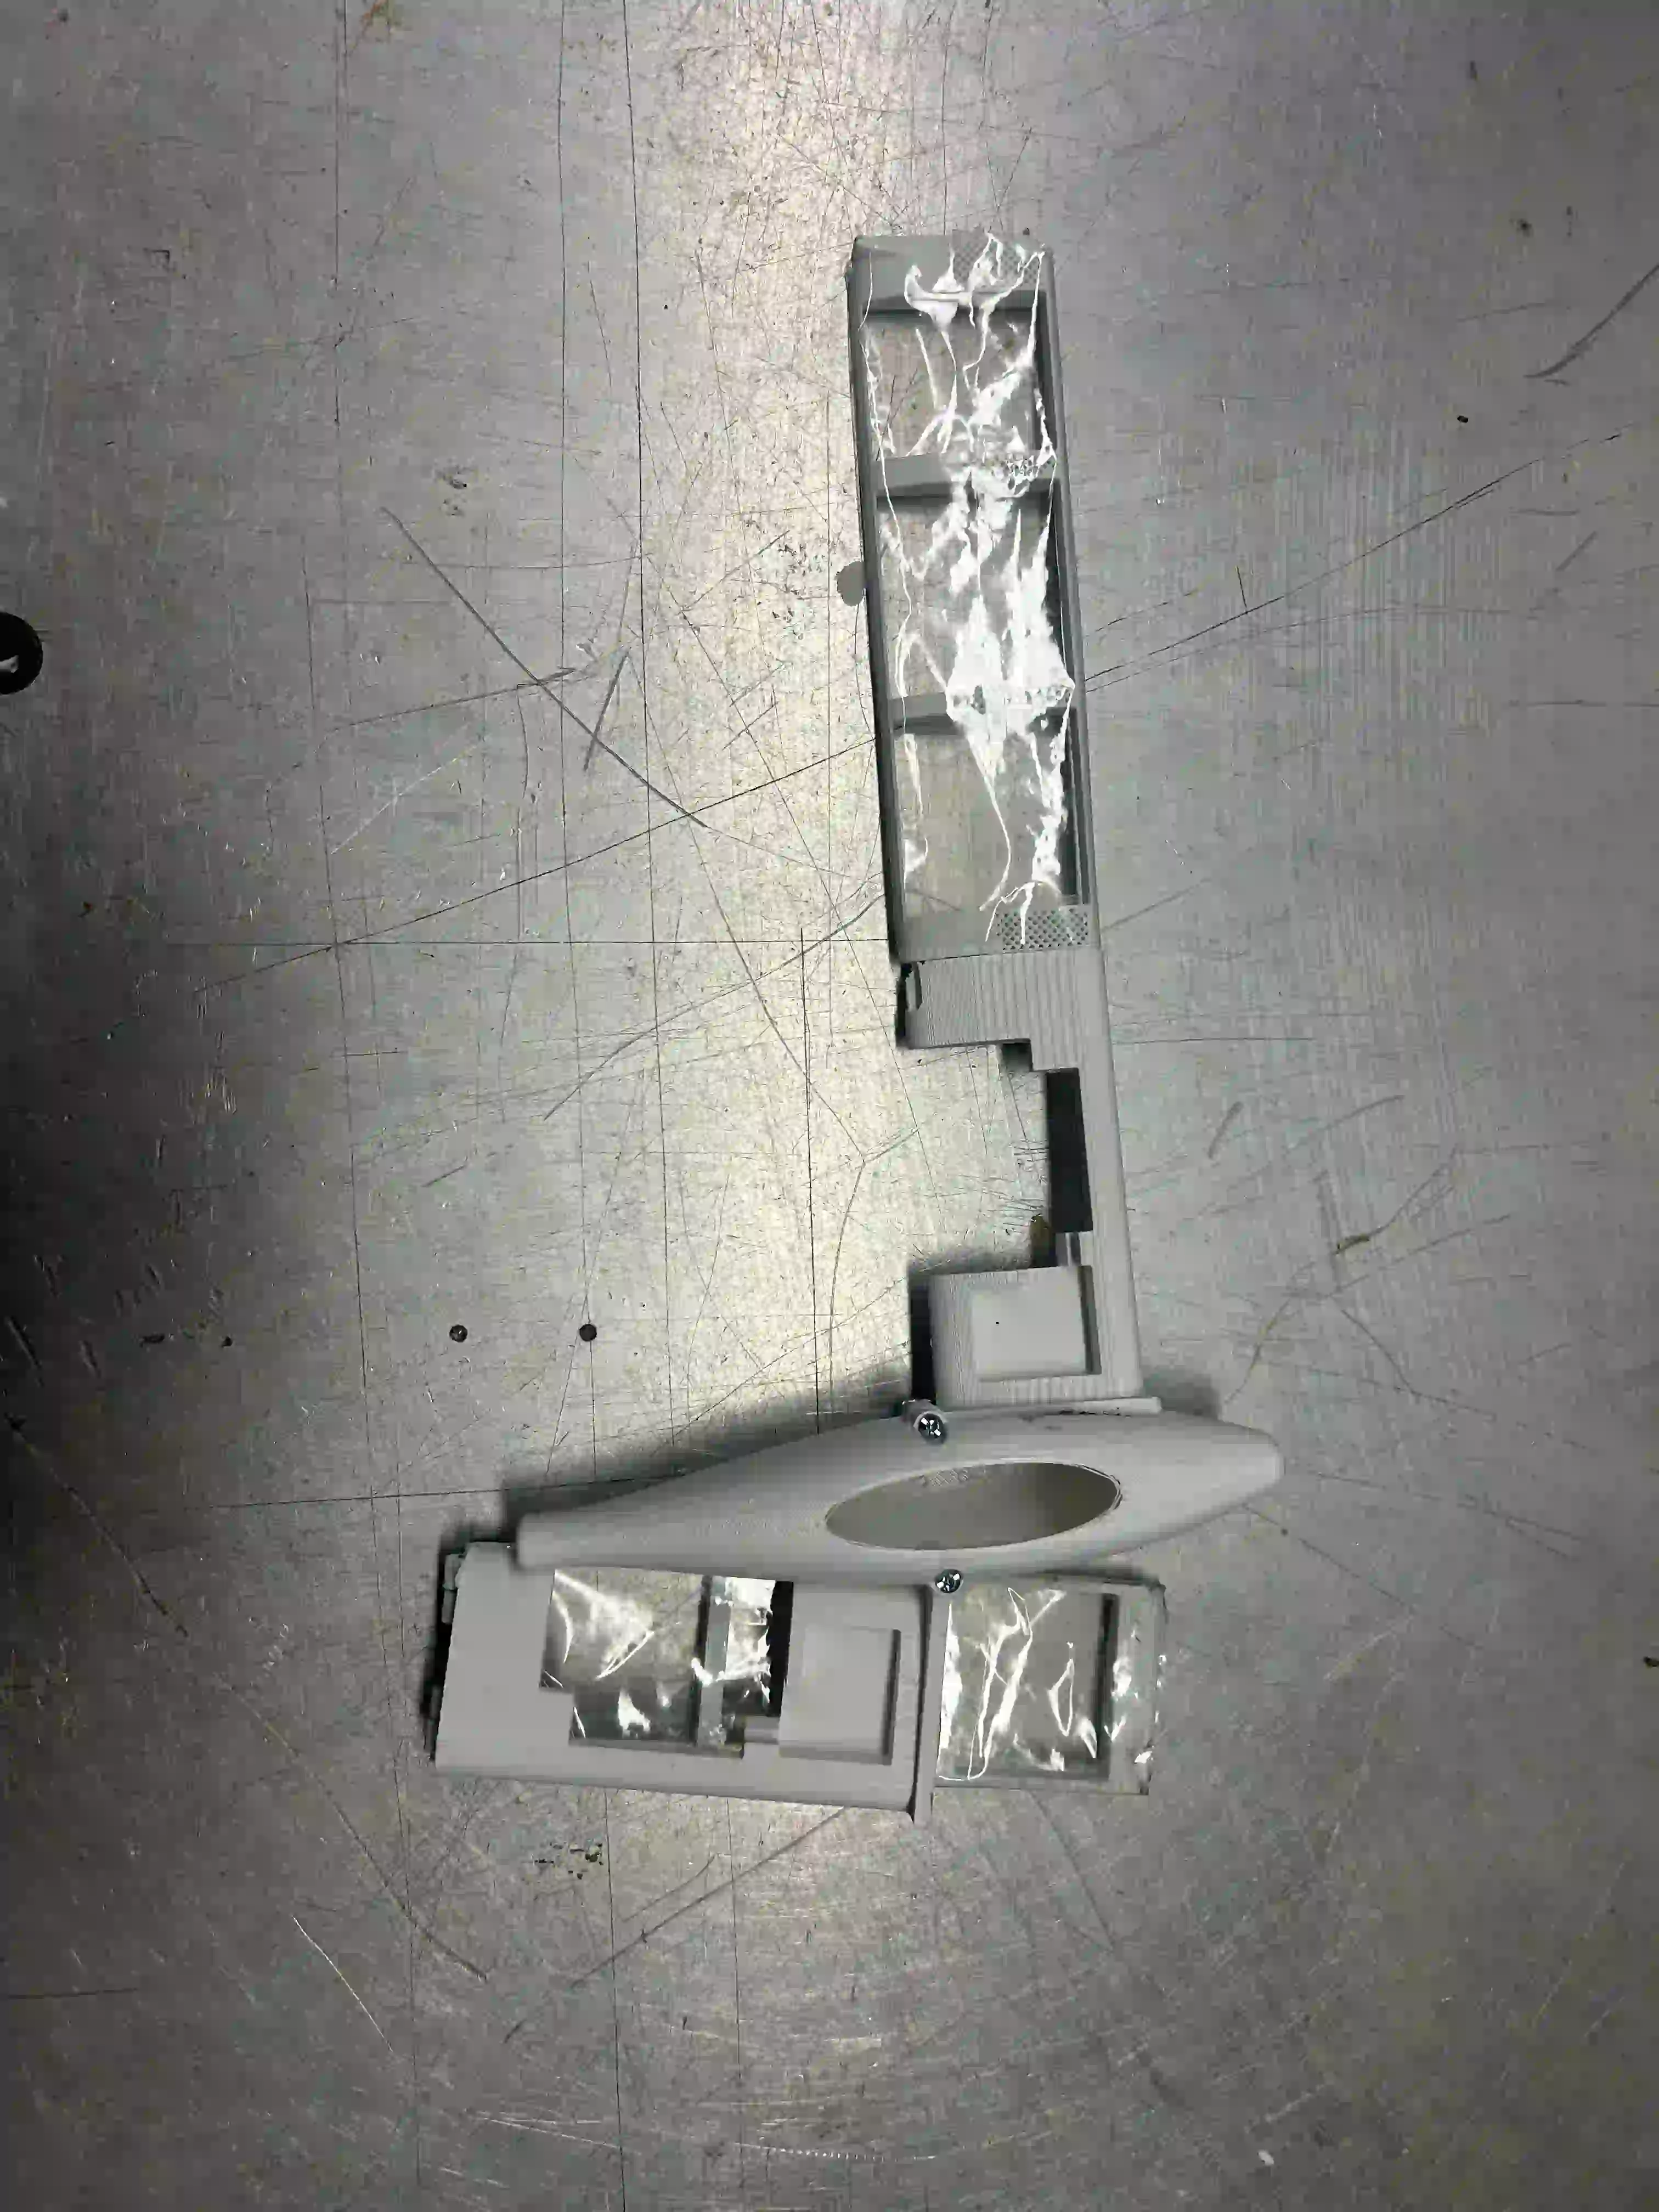
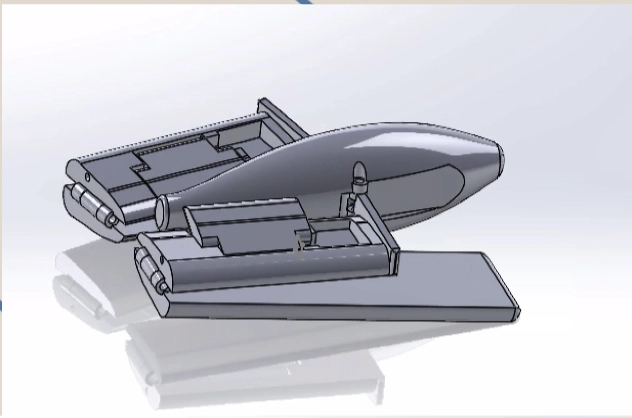
The glider will rely on minimal control surfaces and a small onboard flight controller to reach the target. With no parachute attached, the moment the glider releases from the payload canister, its wings will fold out and it will rely on two servo-controlled ailerons to guide its descent down towards the target.
Gallery
General Specifications
- Mass
- 250 g
- Wingspan
- 66 cm
- Competitions
- 0
Meet the Team
Luke Ricketts
Glider Team Lead
Geneva Brannon
Aerospace Engineering
Thomas Fitzgerald
Physics
Henry Gilmore
Electrical Engineering
Kyler Jacobs
Mechanical Engineering